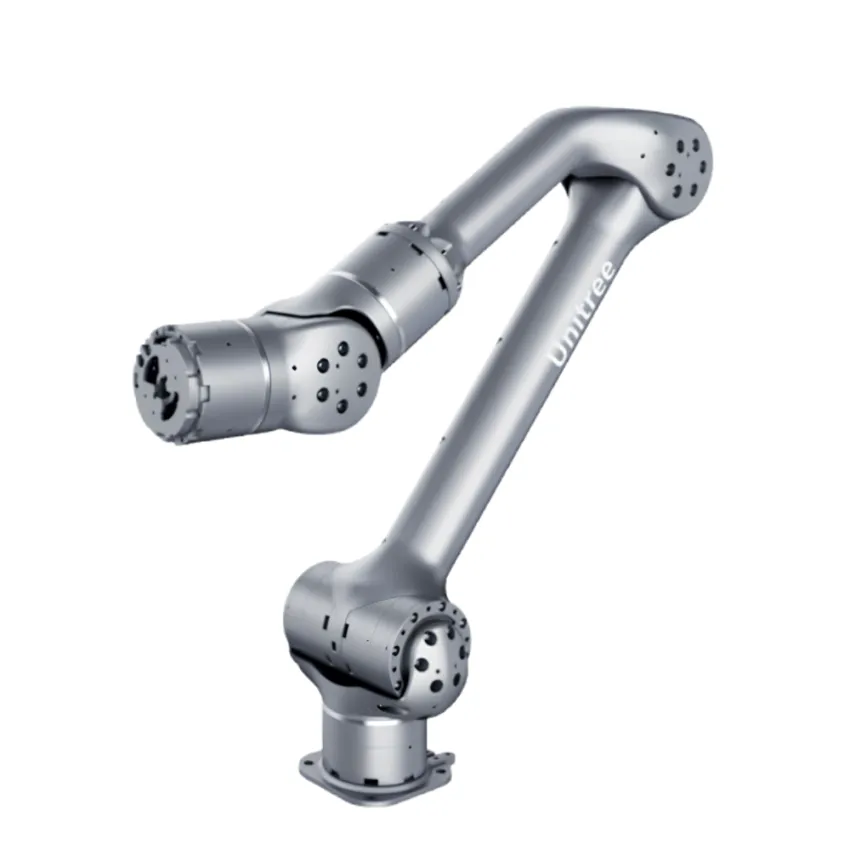
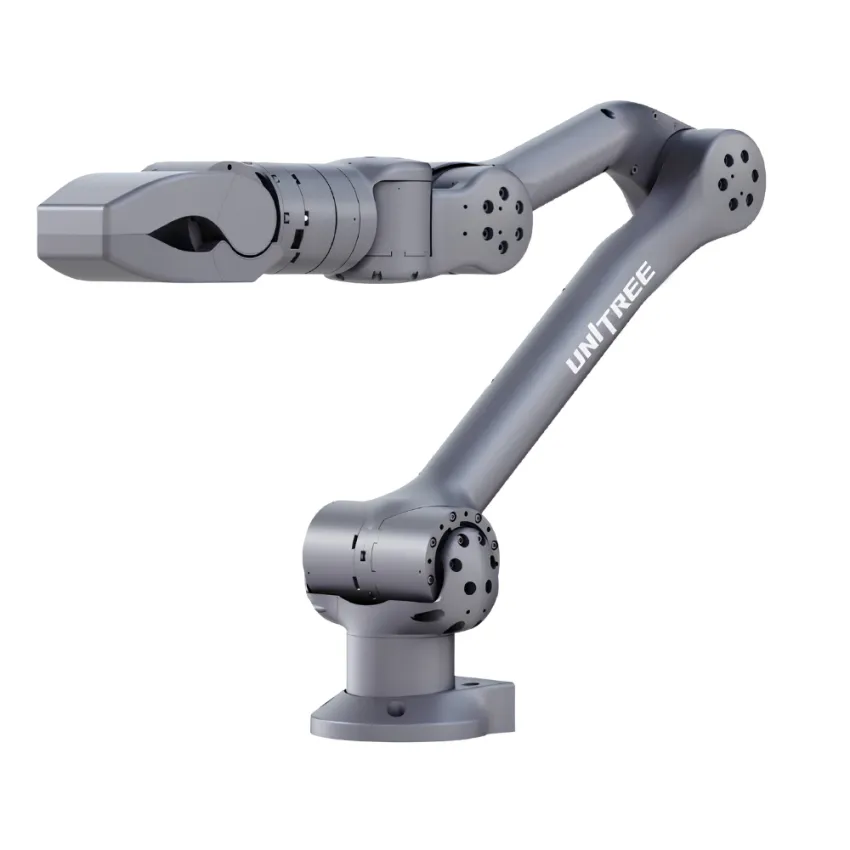
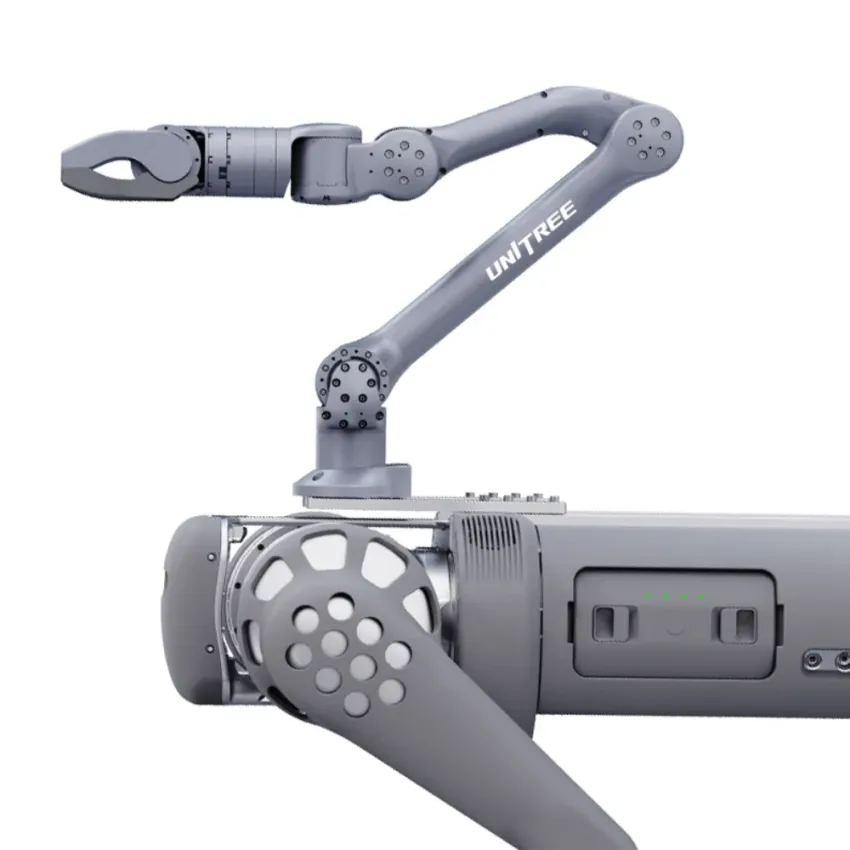
The Unitree Z1 is a compact dexterous robotic arm engineered for advanced manipulation and robotic integration applications.
With 6 degrees of freedom, the Z1 supports precise motion, force control, collision detection, and manual drag-and-drop teaching, making it suitable for robotics development, object manipulation, and research applications.
The Z1 Air provides a 2 kg payload capacity, while the Z1 Pro increases the payload to 3 kg or more and adds higher-performance components with an air-cooled cooling system.
Both versions are designed specifically for integration with the Unitree B2 robot.
Available Arm Configurations:
Z1 Air
• 6 DOF
• Approx. 2 kg payload
• Approx. 4–5 kg arm weight
• Approx. 0.1 mm repeat accuracy
• Sensitive collision detection
• Manual drag-and-drop teaching
• Position control
• Force control
• Designed for Unitree B2 integration
Z1 Pro
• Includes all Z1 Air capabilities
• 6 DOF
• Payload: 3 kg or more
• Higher-performance components
• Air-cooled cooling system
• Sensitive collision detection
• Position control
• Force control
• Designed for Unitree B2 integration
Available Gripper Options:
Z1 Gripper – Standard
• Standard mechanical gripper
• Size: 139 × 80 × 68 mm
• Weight: Approx. 700–750 g
• Tiger-mouth force: 200 N
• Fingertip force: 150 N
• Maximum opening angle: 90°
• Opening / closing time: Approx. 0.5 seconds
• Operating voltage: 24 V
• Peak power: 70 W
• Communication: RS485
Z1 Gripper + Intel RealSense D435i
• Includes all standard Z1 gripper specifications
• Integrated Intel RealSense D435i depth camera
• Ideal sensing range: Approx. 0.3–3.0 m
• Designed for longer-range object recognition
• Depth + RGB sensing
• Camera integrated into the gripper body
Z1 Gripper + Intel RealSense D405
• Includes all standard Z1 gripper specifications
• Integrated Intel RealSense D405 depth camera
• Ideal sensing range: Approx. 7–50 cm
• Designed for close-range precision tasks
• High-resolution close-up depth sensing
• Camera integrated into the gripper body
Technical Specifications:
• Robot Type: Dexterous Robotic Arm
• Degrees of Freedom: 6
• Repeat Accuracy: Approx. 0.1 mm
• Control Modes: Position + Force Control
• Collision Detection: Supported
• Drag-Teach: Supported
• Maximum Joint Torque: 33 N·m per joint
• Reducer: Harmonic Drive
• Reduction Ratio: 60+
• Motor Perception Feedback: Supported
• Motor Control Commands: Supported
Joint Range of Motion:
• J1: ±150°
• J2: 0° to 180°
• J3: -165° to 0°
• J4: ±80°
• J5: ±85°
• J6: ±160°
Recommended Applications:
• Robotic manipulation
• Unitree B2 robotic integration
• Research and development
• Object handling and grasping
• Force-control research
• Robotic perception projects
• Vision-guided manipulation
• AI and robotics laboratories
• Industrial robotics research
• Automation development
Important Note
The Z1 series is designed for the Unitree B2 robot. Exact payload, gripper configuration, vision option, pricing, and delivery lead time depend on the selected Z1 configuration. Please submit a quotation request for confirmed technical and commercial details.


 JORD